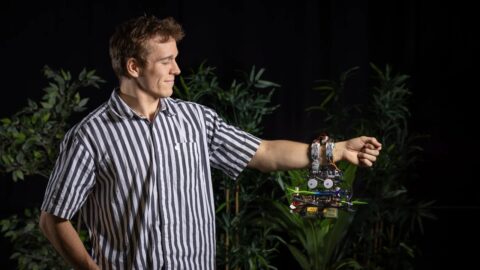
Researchers at the University of California, Berkeley have succeeded in developing the world's smallest wireless flying robot. Only one centimetre in diameter and weighing 21 milligrams, the robot can hover, change direction and hit small targets.
For some time now, researchers have been working on very small flying robots. Until now, the smallest specimen was a robot with a diameter of 2.8 centimetres. However, the specimen from the University of California, Berkeley measures just one centimetre in diameter, making it almost three times smaller....
Inspired by the bee
The robot is inspired by the bee. "Bees exhibit remarkable aeronautical skills, such as navigation, hovering and pollination, that artificial flying robots of similar scale cannot match," explains Liwei Lin, Distinguished Professor of Mechanical Engineering at UC Berkeley and lead author a paper on the research.
Lin: "This flying robot can be wirelessly controlled to approach and hit a designated target, mimicking the pollination mechanism as a bee gathers nectar and flies away."
Powered by external magnetic field
One of the challenges in developing a very small robot is housing a battery and electronics to control the robot. Integrating this into a small and lightweight device is complex.
The robot was therefore designed by the researchers as a small propeller and equipped with two magnets. Under the influence of an external magnetic field, these magnets are pulled towards or pushed away from each other. This causes the robot to start rotating on its axis. Thanks to its design, this generates enough rise force to make the little robot take off. Manipulating the strength of this external magnetic field makes it possible to accurately determine the robot's flight path.
Only passive flying possible
The robot's capabilities are currently limited. For instance, the robot can only fly passively. Thus, the robot does not have sensors for detecting its own position or flight path, and it cannot adjust its movements in real-time.
In practice, this means that the robot can accurately follow a set path, but is unable to react to any changes in its environment such as a gust of wind. The researchers do want to add these capabilities to the robot in time.
The researchers are also considering making the robot even smaller. Currently, a relatively strong magnetic field is needed to manipulate the robot. Reducing the robot further to a diameter of less than a millimetre makes it possible to control the robot with a less strong magnetic field.
Various applications
The researchers see several applications for the very small robots they are developing. "Minuscule flying robots are useful for exploring small cavities and other complicated environments," says Fanping Sui, who recently completed a Ph.D. in engineering at UC Berkeley and is one of the authors of the paper. "This can be used for artificial pollination or inspecting small spaces, such as the inside of a pipe."
The researchers' paper can be found here.
Author: Wouter Hoeffnagel
Image: Pexels via Pixabay