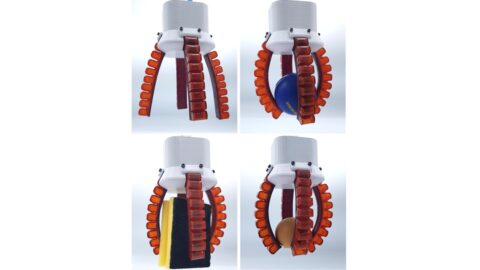
mimic announces two new products: the M1 robotic hand and the U1 wearable, also known as umimic. The U1 is an exoskeleton that allows human movements to be directly translated into the movements of the M1. This enables users to control and train the M1 robotic hand directly via the wearable, using their own movements.
With the M1 and U1, mimic says it aims to enable ‘general-purpose dexterous manipulation’. This term describes the ability of robots to manipulate a wide variety of objects with precision and flexibility, similar to a human. mimic argues that this is only achievable at scale through a fully vertically integrated approach, in which hardware, software and data collection are coordinated. The company draws a parallel with the development of autonomous vehicles.
Combination of data sources
To train the M1, mimic uses a combination of data sources. For instance, mimic uses videos of human actions for pre-training, whilst teleoperation and implementation data are used for post-training. mimic states that it deliberately limits its technology to a robotic hand and does not, for example, develop a two-fingered gripper, as this would require separate training.
“If we base the pre-training on human videos and then deploy a two-fingered gripper, we introduce a cross-embodiment gap. As a result, our pre-training and post-training phases are not properly aligned: the end-effector (the tip of the robotic system that interacts with the environment) is different, and the individual steps a human takes to manipulate an object are not the same steps that a two-fingered gripper would need to perform”, writes mimic in a blog post.
M1 robotic hand
The M1 robotic hand is equipped with joints that are tailored to the most functionally important degrees of freedom of the human hand. In total, the hand has 15 active degrees of freedom distributed across 21 joints. The back torque of the actuators is less than 0.05 Nm, enabling weights from 50 grams to be detected directly via the motor current. A dual-encoder setup makes it possible to recognise touches with an accuracy of 0.1 N. Sensors in the fingertips measure shear forces and contact points.
For the drive system, mimic uses a tendon-driven architecture, in which the motors are located in the forearm rather than in the hand itself. Control is achieved via Bowden cables. This design choice makes it possible to use larger, more powerful and more backdrivable motors than would be possible with fully integrated hands. To prevent wear and variable friction that can occur in Bowden cable-based systems, the tendons are guided through bearings and pulleys. According to Mimic, this ensures a linear and predictable force transmission path.
According to the published specifications, the M1 has a static load capacity of over 25 kg with a cylindrical grip, a fingertip positioning accuracy of ±0.18 mm and a backlash of less than 0.3 degrees. The hand is designed and manufactured in Switzerland by the Swiss-American company.
U1 wearable
The U1 is a passive, user-powered exoskeleton that mimics the movements and tactile sensations of the M1. The wearable is fitted with a coupling mechanism that limits the range of motion of the human hand to that of the M1 robotic hand. This creates a one-to-one coupling for each degree of freedom. The M1’s sensors, encoders and wrist camera have also been replicated on the U1. This allows users to experience the same sensory feedback as the robot.
In terms of dimensions and shape, too, the U1 is tailored to the exact geometry of the M1. This imposes certain limitations: as a result, the U1 wearable is only suitable for users with hands of a certain size. “A wearable system that can adapt to any hand cannot simultaneously enforce the robot’s exact kinematics. That is why we opted for the opposite design trade-off. The geometry is fixed to the robot, meaning the device only works properly for users whose hands fall within a specific size range. On the other hand, the mechanical coupling is direct. Demonstrators feel contact forces through their own fingers, act without control delays or recalibration of movements (retargeting), and perform manipulation tasks at virtually the same natural speed as a human. “As a result, the resulting demonstrations can be collected more quickly and are better aligned with the behaviour the robot is intended to reproduce,” says mimic.
Middleware
mimic is also launching its own middleware stack, called mimic-ipc. This is specifically designed for real-time robot control. The middleware handles communication between the various components of the robot system, such as sensors, actuators and control software. mimic draws a comparison with FastDDS, a widely used communication solution in robotics that is often deployed in conjunction with ROS2 — a popular open-source framework for building robot software. According to the company, compared to FastDDS with shared memory, mimic-ipc achieves a speed gain of approximately 18,000 times when processing HD image data, with a median latency of 89 nanoseconds between processes on separate cores. In terms of jitter – which describes the degree of variation in latency – mimic also claims to perform significantly better than conventional solutions such as ROS2 with FastDDS.