Controlling two asymmetric robotic tasks can be quite a challenge. Researcher Jeroen van Oosterhout developed a system with haptic support that makes it easier to control two robots at the same time. He is writing his PhD on the subject today at TU Delft.
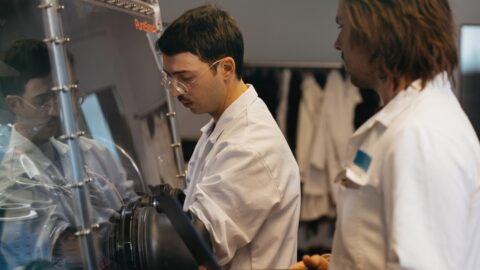
"Normally, we perform maintenance and repair directly by hand. But in some cases this is not possible because the site in question is deep in the sea, for example (for oil extraction) or is nuclear contaminated (e.g. at a future nuclear fusion power plant). Then we use tele-manipulation. In this, an operator controls a special master robot to move a slave robot in the task environment. But the slave robot cannot move just any weight. Too-heavy parts we lift with a crane; but this still requires the slave robot for accurate placement. We are then talking about cooperation with two asymmetric slaves,'' says Jeroen van Oosterhout.
Nuclear fusion
Operators of such systems have to go through rigorous selection and training. "Despite this, working with these two systems takes up to 23 times longer than working directly by hand. This has to be improved. The success of future fusion power plants, for example, largely depends on their operational time. A determining factor in this is the maintenance of those power plants, which must be carried out via tele-manipulation. This maintenance is complex. Therefore, I investigated the impact of interface design choices and haptic support (the operator then feels a guiding force) to improve the coordination between two asymmetric slaves and thus save time."
Variants
Many solutions exist for operator-slave interface, but only two main variants: two cooperating operators, or one individual operator. Haptic support is known to effectively support an individual operator through forces on the interface. But to coordinate information between the two slaves, van Oosterhout had to design a new haptic assistance controller. This new haptic assistance system helps operators coordinate across two asymmetric telerobots by haptically linking the interfaces via task definition.
Remarkable
The new haptic assistance appears to significantly improve task performance, both for two cooperating operators and one. "And remarkably, two operators without support perform significantly better than one operator, but this difference disappears when both cases are haptically supported. Thus, haptic support enables one operator to perform the asymmetric interactive subtasks as well as the two operators together."
Source: TU Delft.