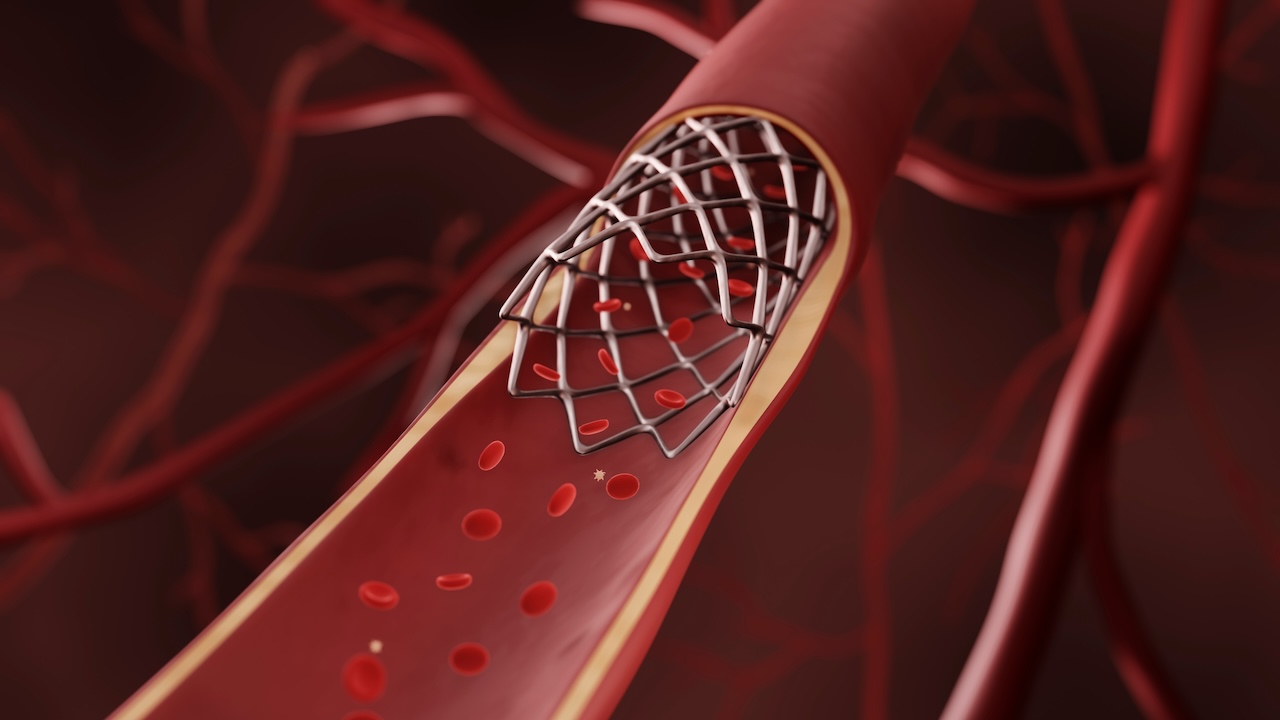
A new robotic platform can allow small, soft and flexible robots to autonomously navigate through a human's blood vessels using artificial intelligence (AI). This will allow interventions to treat blood clots, for example, to be performed safer, faster and less invasive.
The platform was developed by researchers at Concordia University. The method uses small, soft and flexible robots. These are manufactured from a biocompatible rubber-like material containing microparticles, allowing them to be controlled wirelessly using external magnets.
Making treatments safer
The researchers argue that the platform reduces risks such as damaging or perforating vessel walls, making treatments safer. "Wireless magnetic fields open up many application possibilities for healthcare and minimally invasive surgery," said Ramin Sedaghati, professor in the Department of Mechanical, Industrial Design and Aerospace Engineering at the Gina Cody School of Engineering and Computer Science and one of the authors of the paper.
"These small magnetic soft robots attach to the ends of conventional catheters and surgical wires, allowing surgeons to direct the robot by cable to obstacles, perform the procedure and withdraw it with less risk." During testing, the system reduced the number of 'navigation errors' by up to 77% compared to conventional methods. The researchers also report that the steering required less effort.
Controlled by a robotic arm
To travel through blood vessels, the robots are about a millimetre in size. The robots are controlled using a powerful magnet mounted on a six-axis robotic arm. By adjusting the angle and position of the magnet, the researchers can precisely bend and move the soft robot.
Magnetic robotic systems are not new. The researchers report that many existing platforms use so-called open-loop control methods, in which control takes place without feedback on actual position or speed. The system executes preset instructions but does not take into account or correct any deviations.
However, the new robotic platform uses a closed-loop control system, which continuously measures the robot's position and compares it to the desired values. This makes it possible to adjust the control during navigation for any deviations, increasing accuracy.
AI models
The robotic platform uses an AI model developed by the researchers. This model combines analytical methods with deep learning to predict the robot's behaviour. It takes into account changing magnetic forces, gravity and fluid flows as they occur in the human body.
A second deep-learning model detects the shape and position of the robot's tip based on images from a high-speed camera. This model allows real-time tracking of the robot's position and deformation, which allowed the researchers to provide feedback to refine the platform's operation.
Experiments
The platform was tested with a series of in vitro experiments that mimicked real surgical conditions. In addition, the researchers built transparent fluid channels that simulated vascular environments with flowing fluid. The experiments showed
The closed-loop control system consistently outperformed conventional control methods during the experiments, with greater accuracy, stability and resistance to disruptions caused by fluid flow.
The researchers published the results of their research in Smart Materials and Structures.