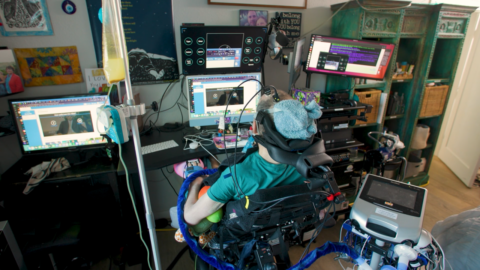
A new robot developed by the University of Washington can significantly increase the independence of people who need support with eating and drinking. The robotic arm is able to give users food and drink completely autonomously.
Patients may be unable to eat and drink independently due to a variety of reasons. This makes this group significantly dependent on third parties, which affects their independence and increases dependency. Also, providing such support is time-consuming and therefore burdensome.
Robotic arm
Researchers at the University of Washington have trained a robotic arm to assist users with eating and drinking. Among other things, the robot is capable of independently determining what types of food are on a plate and can autonomously determine how best to pick up this food and put it in the user's mouth. The robotic arm can be attached to a wheelchair so that it is always at hand.
"Being dependent on a caregiver to feed every bite daily impairs a person's sense of independence," said Siddhartha Srinivasa, a professor at the University of Washington's Paul G. Allen School of Computer Science & Engineering. "Our goal with this project is to give people a little more control over their lives."
Inspired by humans
The operation of the robotic arm is largely inspired by humans. Humans eat all kinds of food, each of which is picked up differently. Thus, not only does the way humans close their hand around a piece of food to pick it up vary, but also the force with which a piece of food is grasped. To visualise these differences, the researchers set up a test in which volunteers had to pick up different types of food. Sensors were used to record this process.
This experiment also showed that people not only ensure that a piece of food is picked up efficiently, but in doing so, they also consider how best to put it in the mouth. By turning and manipulating the food, we adjust the orientation of the piece of food so that it can be eaten as easily as possible. As an example, Tapomayukh Bhattacharjee, a postdoctoral researcher at the university, mentions a carrot. "You can pick up a carrot by poking it in the middle, but then it is difficult to eat," Bhattacharjee says. "If you pick it up by one of the ends and then turn it towards someone's mouth, it is much easier to take a bite."
Algorithms
The robotic arm uses two algorithms. One algorithm called RetinaNet identifies the different types of food on a plate and places a frame around each type. A second algorithm called SPNet then determines for each frame how best to pick up the food and offer it to a person. The combination was tested during an additional experiment, in which a robotic arm was able to give subjects food.
"Our ultimate goal is that our robot can help people eat lunch or dinner independently," explains Srinivasa. "However, we do not aim to replace caregivers: rather, we want to support them. With a supportive robot, a caregiver can prepare a plate and, while the person eats, do something else themselves."
Robotic arm in action
The robotic arm is demonstrated in the video below.
In a paper in IEEE Robotics and Automation Letters, the researchers provide more information about their robotic system.
Author: Wouter Hoeffnagel
Source: University of Washington