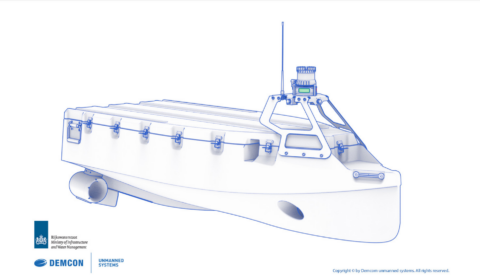
Researchers from TU Delft, Wageningen University and the Massachusetts Institute of Technology (MIT) carried out a first demonstration with self-propelled boats in Amsterdam last week. The so-called Roboats should eventually be used to reduce congestion in busy, water-rich city centres.
The Roboat has now completed its second year of research. The past year saw some significant results, including making the vehicles autonomous and a locking system that allows the boats to link and dock individually. The extent to which the boats could be useful in waste disposal and food distribution was also investigated.
Autonomy achieved
But how does such a robotic craft move through Amsterdam's canals? The Roboat is able to determine the best route from point A to B. Not only does it determine how busy it is on the water, it also takes into account the unique characteristics of the canals and bridges and possible obstacles it may encounter along the way. To accelerate the research and development of autonomous navigation technology, current prototypes are being developed to a scale of 1:4.
The vessel's position is determined using LIDAR (Laser Image Detection and Ranging), to which GPS sensors are also added. The laser radar maps the environment very precisely, and when the Roboat encounters an obstkeln in the water, it can determine whether it is fixed or moving and how far away it is from the object. It then determines the best manoeuvre to avoid the obstacle, then continues on the most optimal route. Several algorithms teach the boat to recognise the behaviour of different objects and other vessels on the water. The more time the boat navigates through the canals, the better the estimates become.
"What is unique about the autonomous techniques we applied to the Roboat is that the control system is quite challenged in the challenging urban environment of Amsterdam. Testing the Roboat in the canals of this city gives us good insights to improve the control system for environments like this. This is something that has not been done in previous projects for autonomous vessels," said Carlo Ratti, the director of the MIT Senseable City Lab.
Temporary infrastructures
Because the vessels can be linked together, temporary infrastructures can be set up to make bridges or platforms, or Roboat units can act as push and tow boats. In the second year of research, the mechanism for locking or linking ships to the quay was further developed. The ships can determine each other's position on the water using GPS. When the vessels have approached each other sufficiently to come into view, LIDAR takes over the local positioning. Once closer, the camera is used, which recognises visual indicators of the locking mechanism. This is the final step before the mechanism is activated and the ships are linked together or driven to the quay.
The makers think autonomous boats could come in handy in a crowded city like Amsterdam, which also has a lot of water running through it. "Since 25 per cent of Amsterdam consists of water surface, this is the ideal environment to expand its current infrastructure with the implementation of autonomous boats. This would take the pressure off the relatively small but busy city centre. For example, if waste were collected on the water, it would reduce traffic movements on the streets. The containers would be placed in the water, so the beautiful view of the canals would also not be ruined.
Further research
Further development of the Roboat continues. In the third year, researchers will focus on developing a prototype on the scale of 1 in 2, testing urban transport, improving the energy system and propulsion system and developing new sensors to measure water quality, among other things.
Source: AMS/De Ingenieur